
ASRLab continuously develops its research infrastructure to support advanced studies in artificial intelligence, Digital Twins, autonomous systems, robotics, extended reality, software testing, and verification and validation. The laboratory combines high-performance computing resources with robotic and experimental platforms, enabling researchers to move from simulation and software development to physical experimentation, system validation, and industrially relevant research scenarios.
High-Performance Computing
Excalibur Gaming E650 Workstation
Intel Core i7-14700F · NVIDIA GeForce RTX 4060
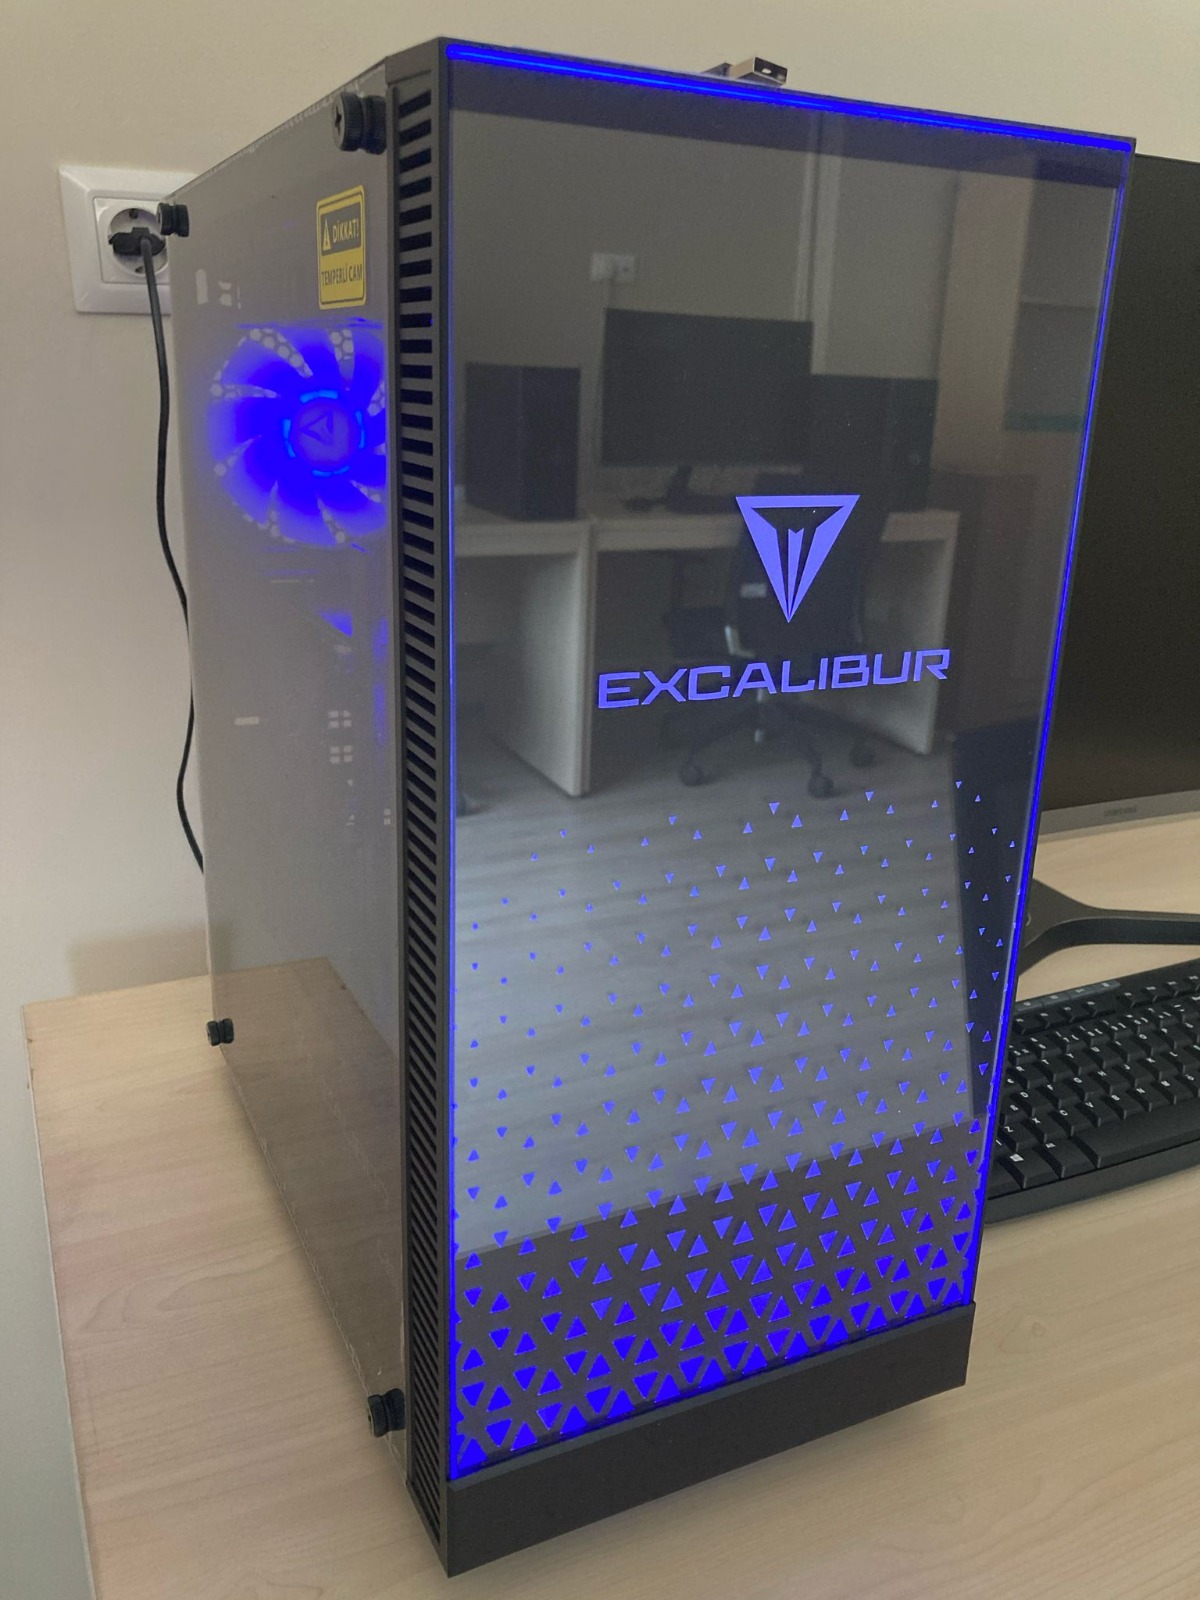
The Excalibur Gaming E650 is used as a high-performance computing platform for artificial intelligence, machine learning, data analysis, robotic simulation, and software engineering research.
- Its Intel Core i7-14700F processor and NVIDIA GeForce RTX 4060 GPU provide GPU-accelerated computing capabilities for deep learning, AI-assisted software testing, computer vision, simulation, and data-intensive research workflows.
Research Applications:
AI & Machine Learning · Robotics Simulation · 3D Modelling · Data Analysis · Scientific Computing · AR/VR Development
Dell Precision 3680 Workstation
Intel Core i9-14900 · NVIDIA RTX 4000 Ada Generation
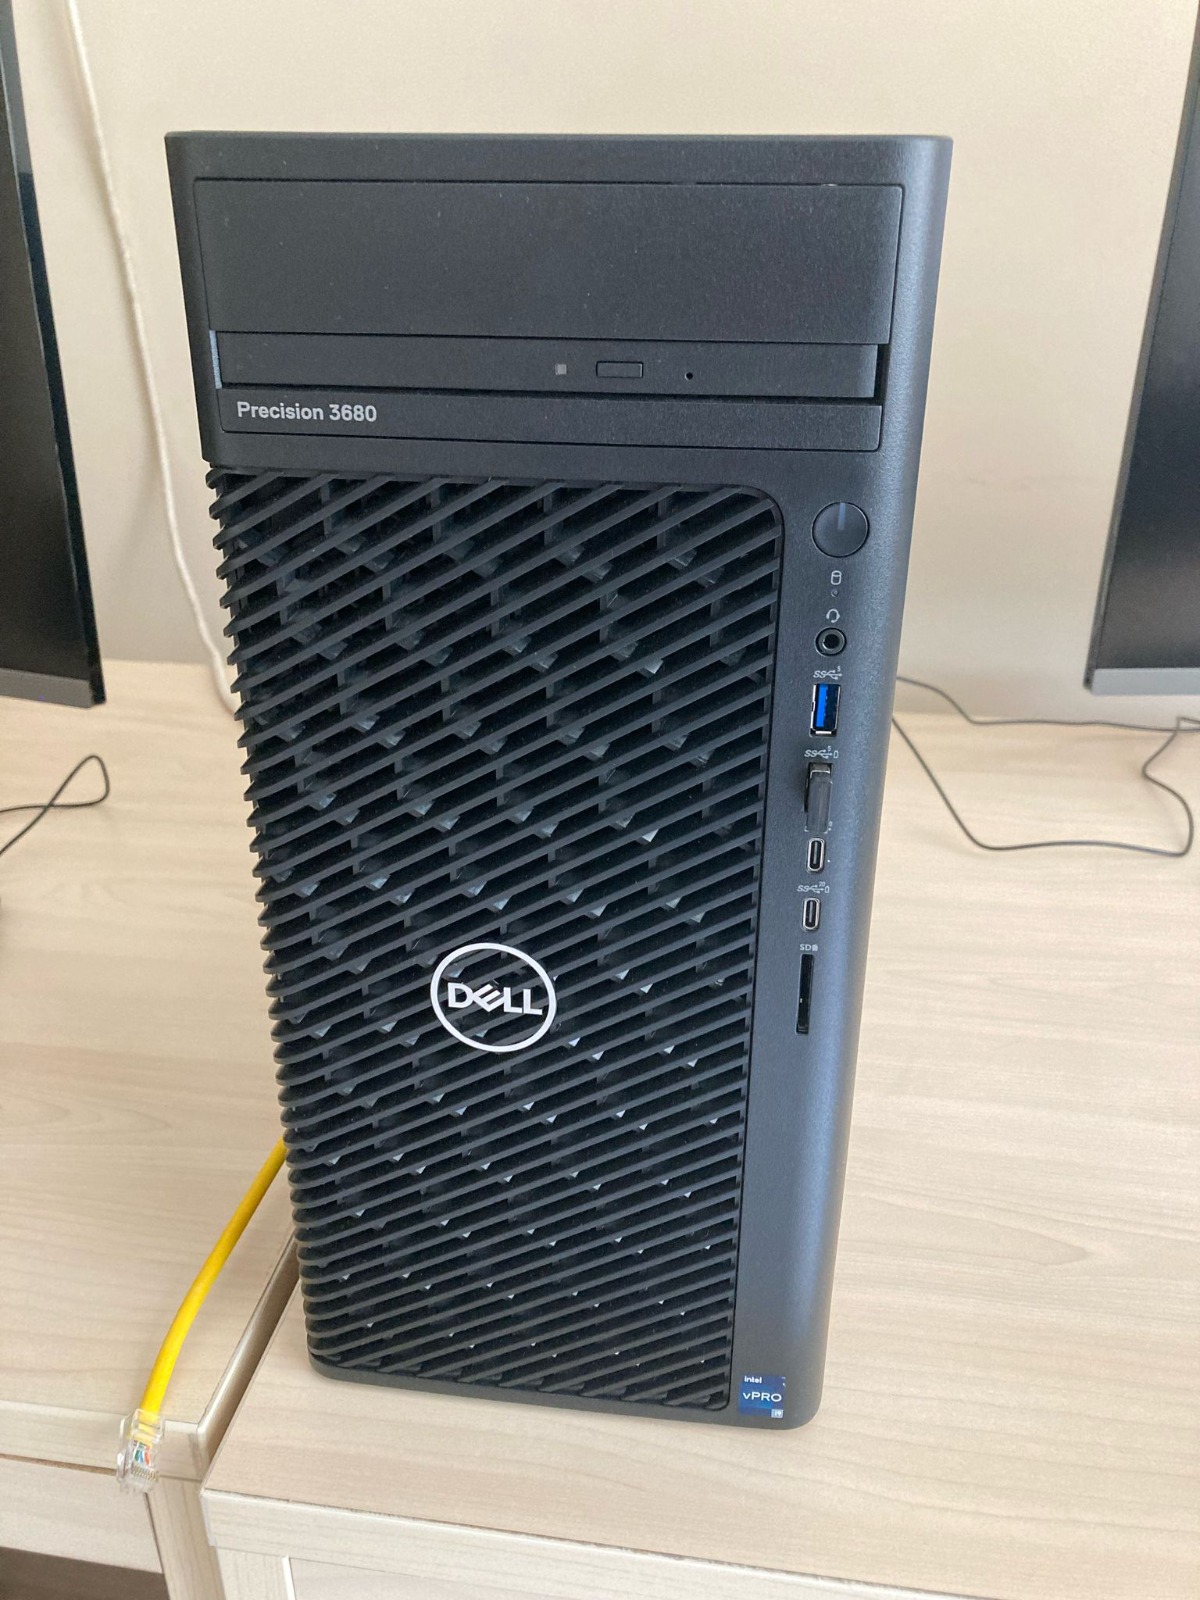
The Dell Precision 3680 is ASRLab's professional high-performance workstation for computationally intensive research activities.
- Equipped with an Intel Core i9-14900 processor and NVIDIA RTX 4000 Ada Generation GPU, the workstation supports AI model development, LLM-related research, Digital Twin simulation, robotics, engineering analysis, 3D modelling, and large-scale data processing.
- Its professional GPU architecture and high-memory capabilities make it particularly suitable for advanced simulation, deep learning, robotics, and engineering workloads.
Research Applications:
AI & Machine Learning · Digital Twins · Robotics Simulation & Control · Scientific Computing · Data Analytics · 3D Modelling · AR/VR Development
Robotics & Automation Infrastructure
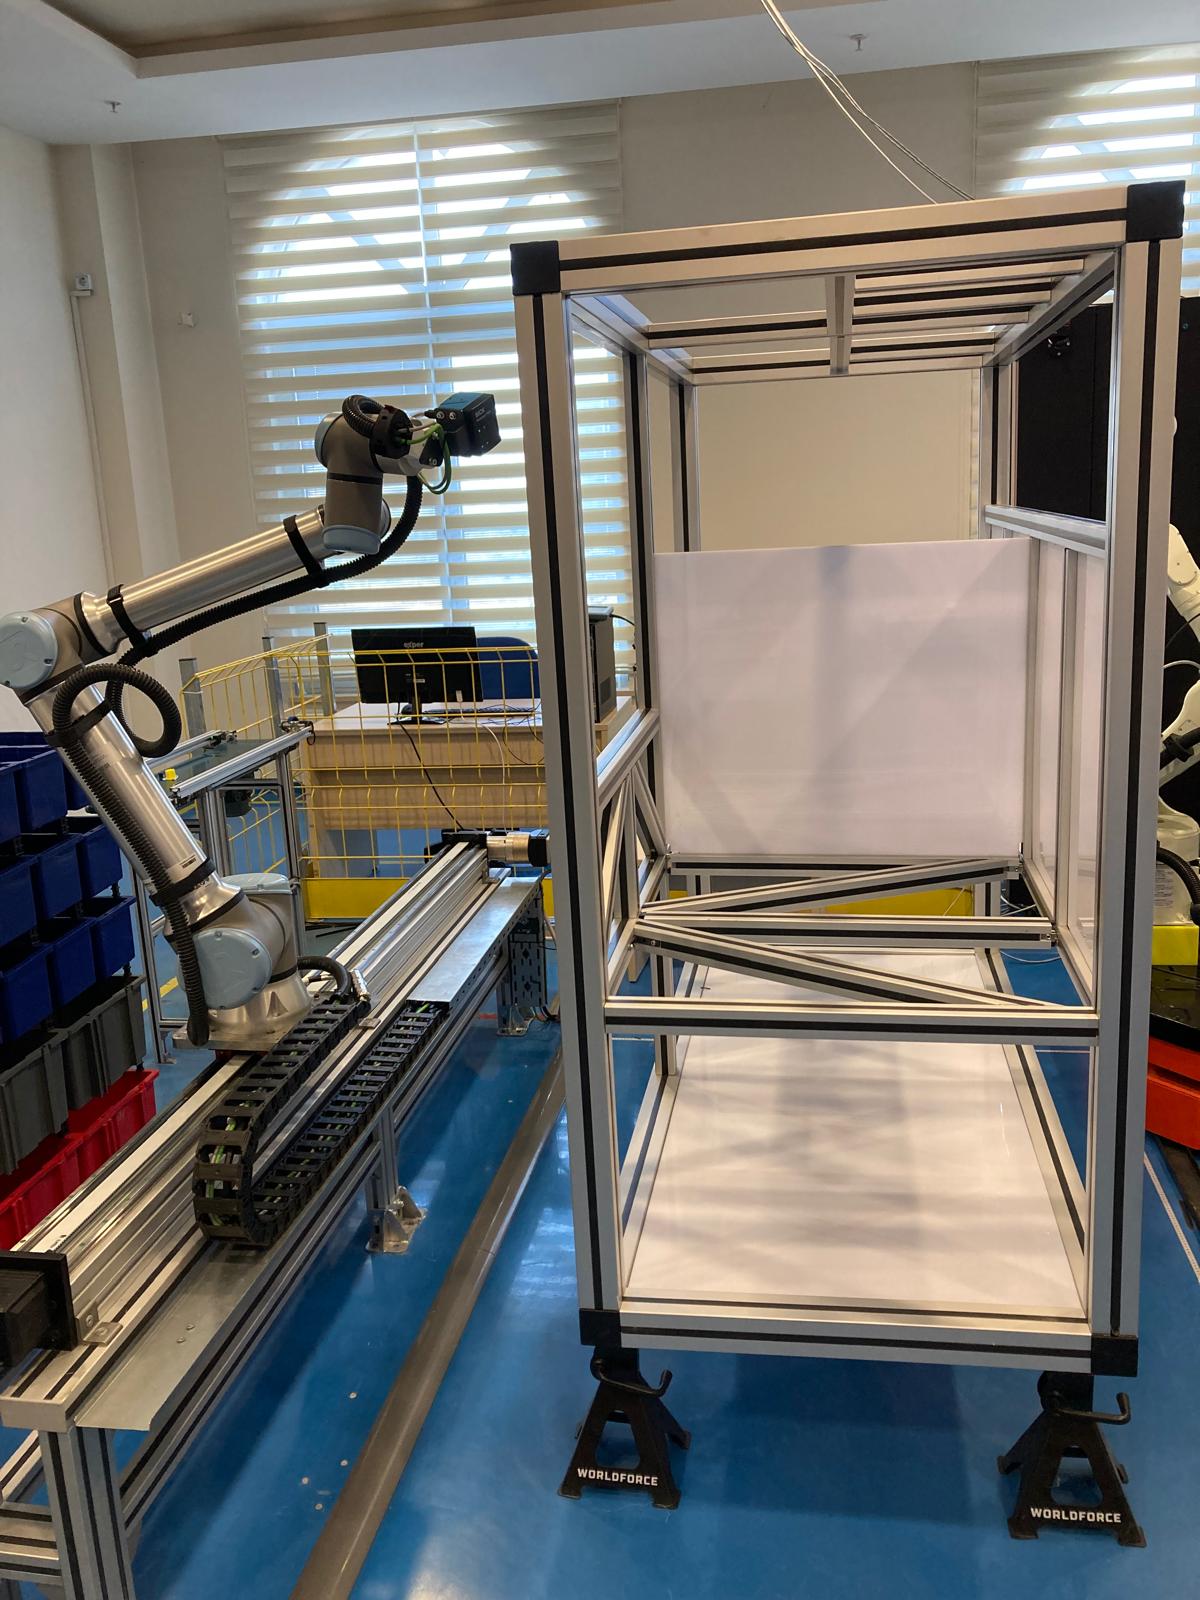
Universal Robots UR10e Collaborative Robot
 dd
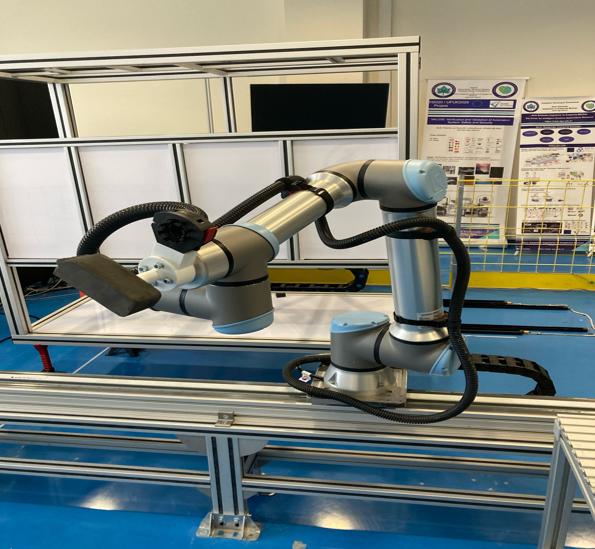
- The Universal Robots UR10e is the core robotic platform of ASRLab's automation and experimental robotics infrastructure.
- The six-axis collaborative robot supports research in manipulation, industrial automation, human–robot collaboration, robotic inspection, verification and validation, and intelligent manufacturing.
- Its modular architecture allows different end-effectors, sensors, and experimental tools to be integrated depending on the research scenario.
Research Applications:
Robotics · Human–Robot Collaboration · Automated Inspection · Pick-and-Place · Assembly · Verification & Validation
End-Effectors & Robot-Mounted Equipment
The UR10e platform can be configured with different end-effectors, tools, and perception systems, allowing the same robotic platform to support a wide range of experimental scenarios.
OnRobot Dual Quick Changer
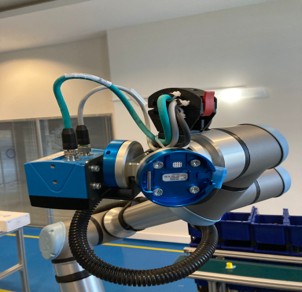
- The OnRobot Dual Quick Changer enables two compatible tools to be mounted on the UR10e simultaneously.
- It provides rapid, tool-free switching between end-effectors and automatically establishes the required mechanical, power, and data connections.
Applications:
Multi-Tool Robotics · Flexible Automation · Pick-and-Place · Assembly
OnRobot 2FG14 Gripper
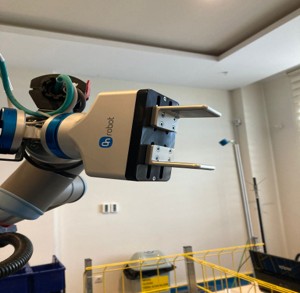
- The OnRobot 2FG14 is an electric two-finger parallel gripper used for programmable robotic grasping and material-handling experiments.
- Its configurable gripping force and intelligent grip detection support the handling of objects with different geometries and weights.
Applications:
Robotic Grasping · Material Handling · Assembly · Tool Handling
OnRobot VGC10 Vacuum Gripper
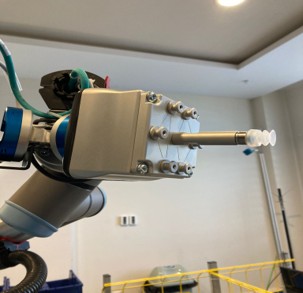
- The OnRobot VGC10 is an electric vacuum gripper used for manipulating objects with different surfaces and geometries.
- Its integrated vacuum system and configurable suction-cup arrangement make it suitable for flexible pick-and-place and panel-handling experiments.
Applications:
Pick-and-Place · Panel Handling · Packaging · Material Handling
SICK Visionary-T Mini 3D Camera
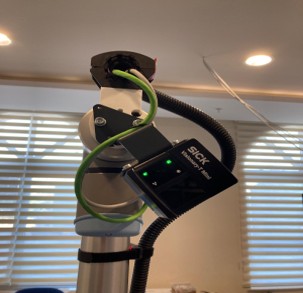
- The SICK Visionary-T Mini is a robot-mounted 3D time-of-flight camera used for robotic perception and automated inspection research.
- Mounted on the UR10e through a custom flange, the camera can capture depth information from different viewpoints as the robot moves through its workspace.
Applications:
3D Machine Vision · Robotic Inspection · Object Detection · Dimensional Measurement · Quality Inspection
SICK sensingCam SEC100
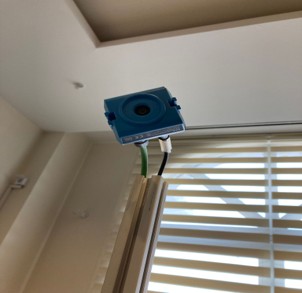
The SICK sensingCam SEC100 is an industrial streaming camera integrated into the robotic cell to provide a wide-angle view of the complete experimental setup.
Unlike the robot-mounted Visionary-T Mini, the sensingCam monitors the overall cell, including the UR10e, linear axis, conveyor, and associated automation equipment. It supports real-time remote observation, experiment recording, error analysis, and visual data collection.
Its Ethernet-based live streaming and browser-accessible interface make it suitable for continuous monitoring and documentation of robotic experiments.
Applications:
Remote Process Monitoring · Experiment Recording · Error Analysis · Data Collection for AI · Robotics & Automation
UR10e Linear 7th Axis
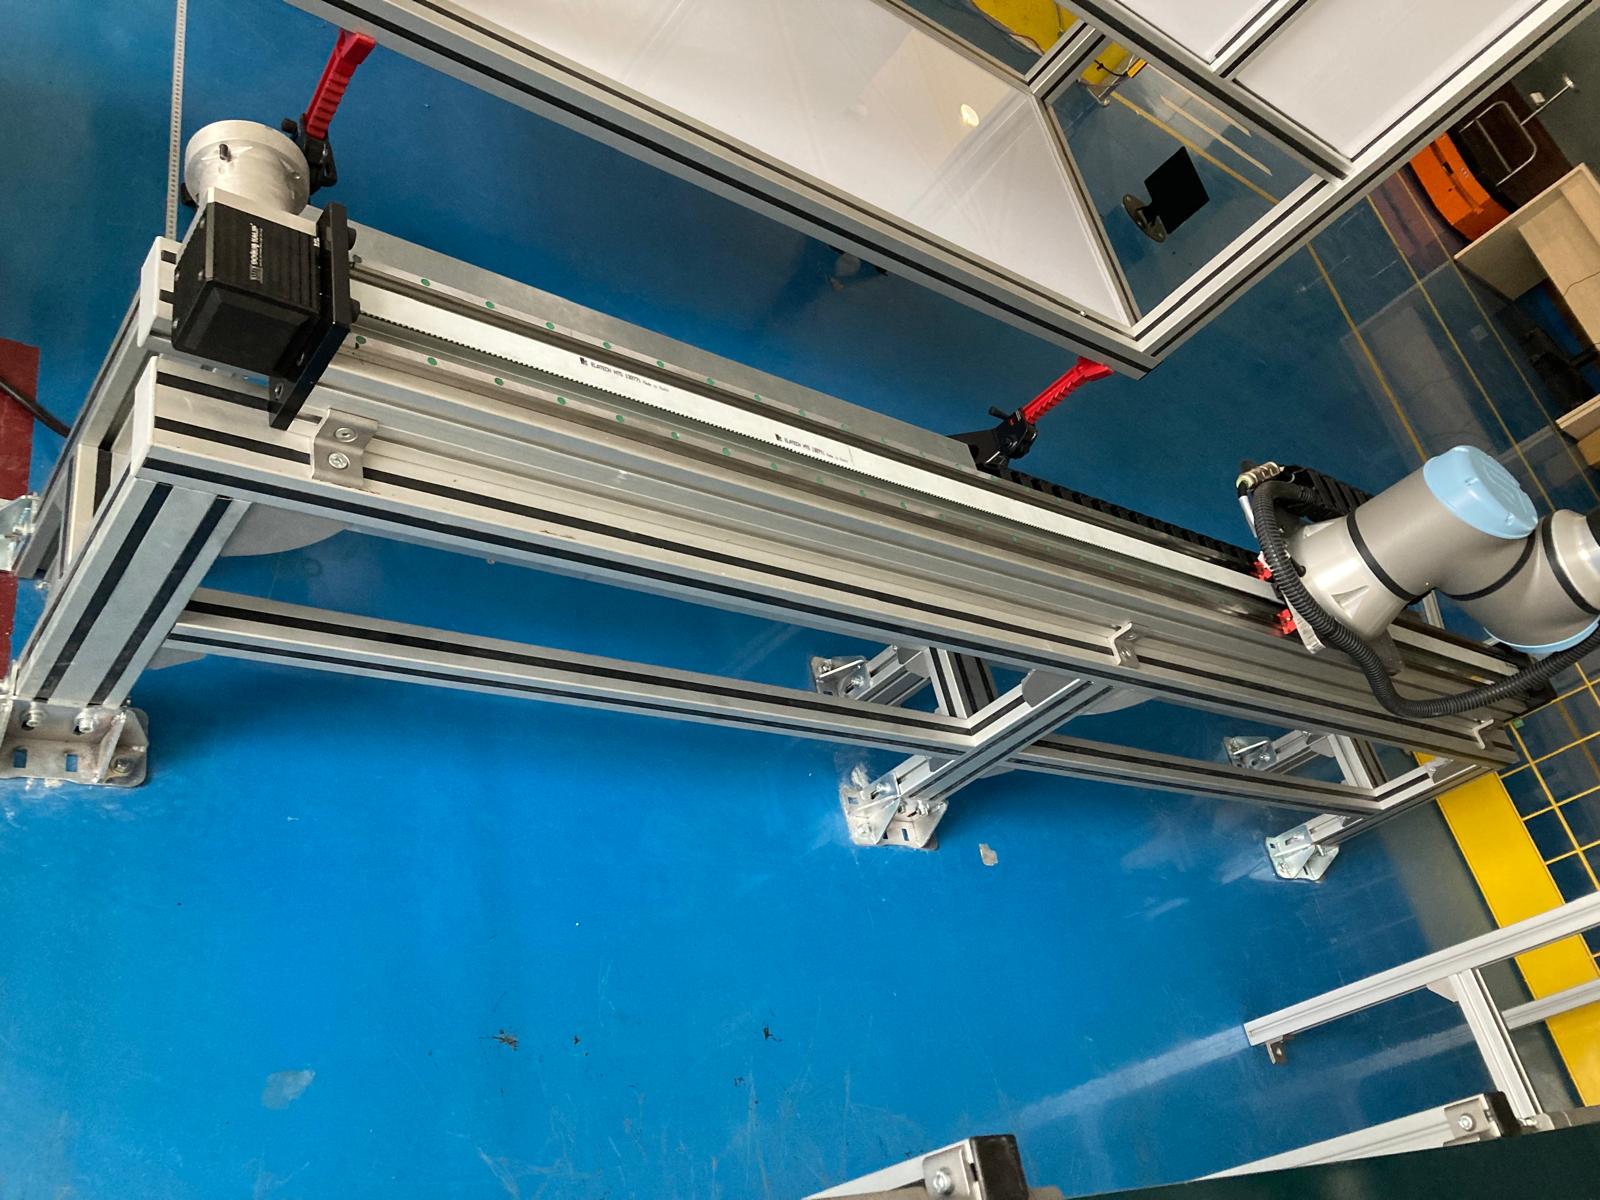
The UR10e robotic platform is extended with a linear seventh axis, increasing the robot's operational workspace and enabling movement across larger experimental environments.
- The system uses a Festo drive and motor and communicates with the UR10e through Modbus, allowing coordinated robot and linear-axis motion.
- This extension is particularly useful for experiments requiring increased workspace coverage, including robot-assisted inspection, material handling, and automated pick-and-place scenarios.
Research Applications:
Extended Robot Workspace · Automated Inspection · Robotics & Automation · Human–Robot Collaboration
Conveyor Belt System
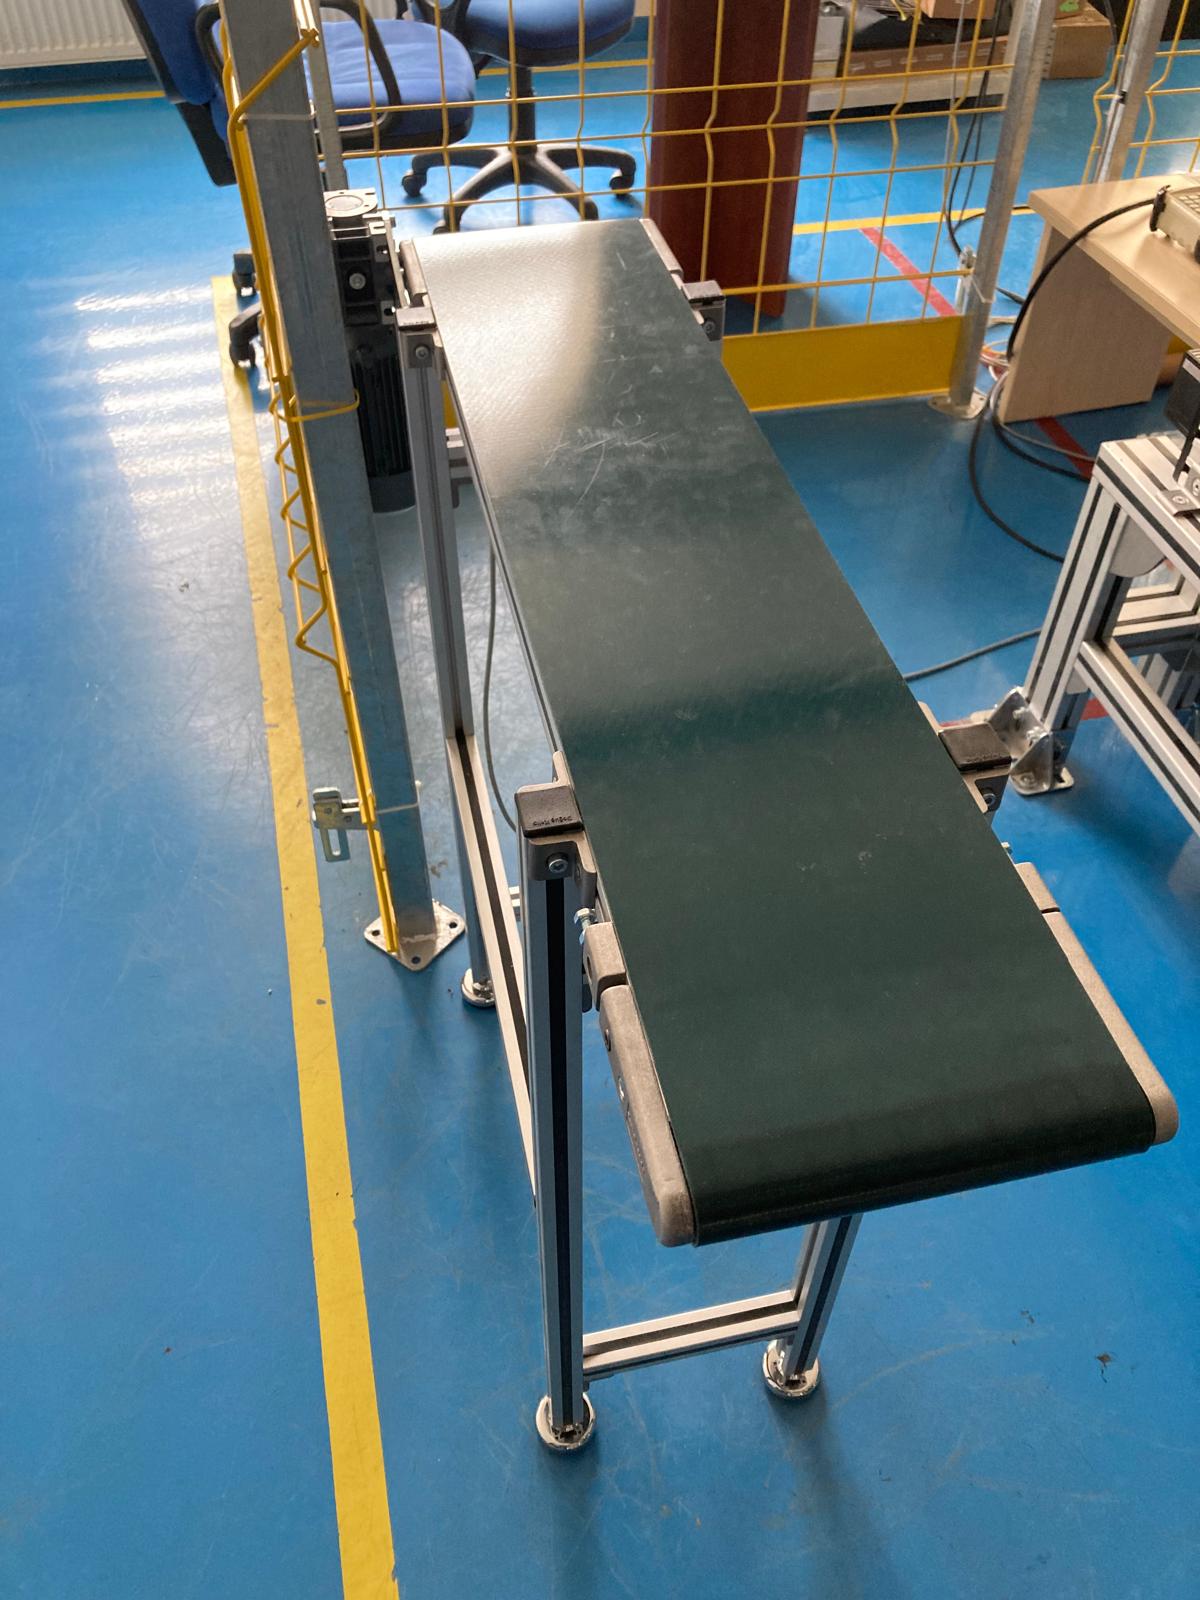
The conveyor belt provides an industrial material-handling environment for robotic automation experiments.
- Integrated with the UR10e platform through analog and digital communication, the system enables synchronised robotic operations and real-time interaction between moving workpieces and robotic systems.
- It supports experiments involving pick-and-place operations, automated material handling, perception, robot coordination, and human–robot collaboration.
Research Applications:
Robotic Automation · Pick-and-Place · Material Handling · Robot Coordination · Human–Robot Collaboration
Experimental Inspection Infrastructure
Automotive Door Panel Inspection Setup
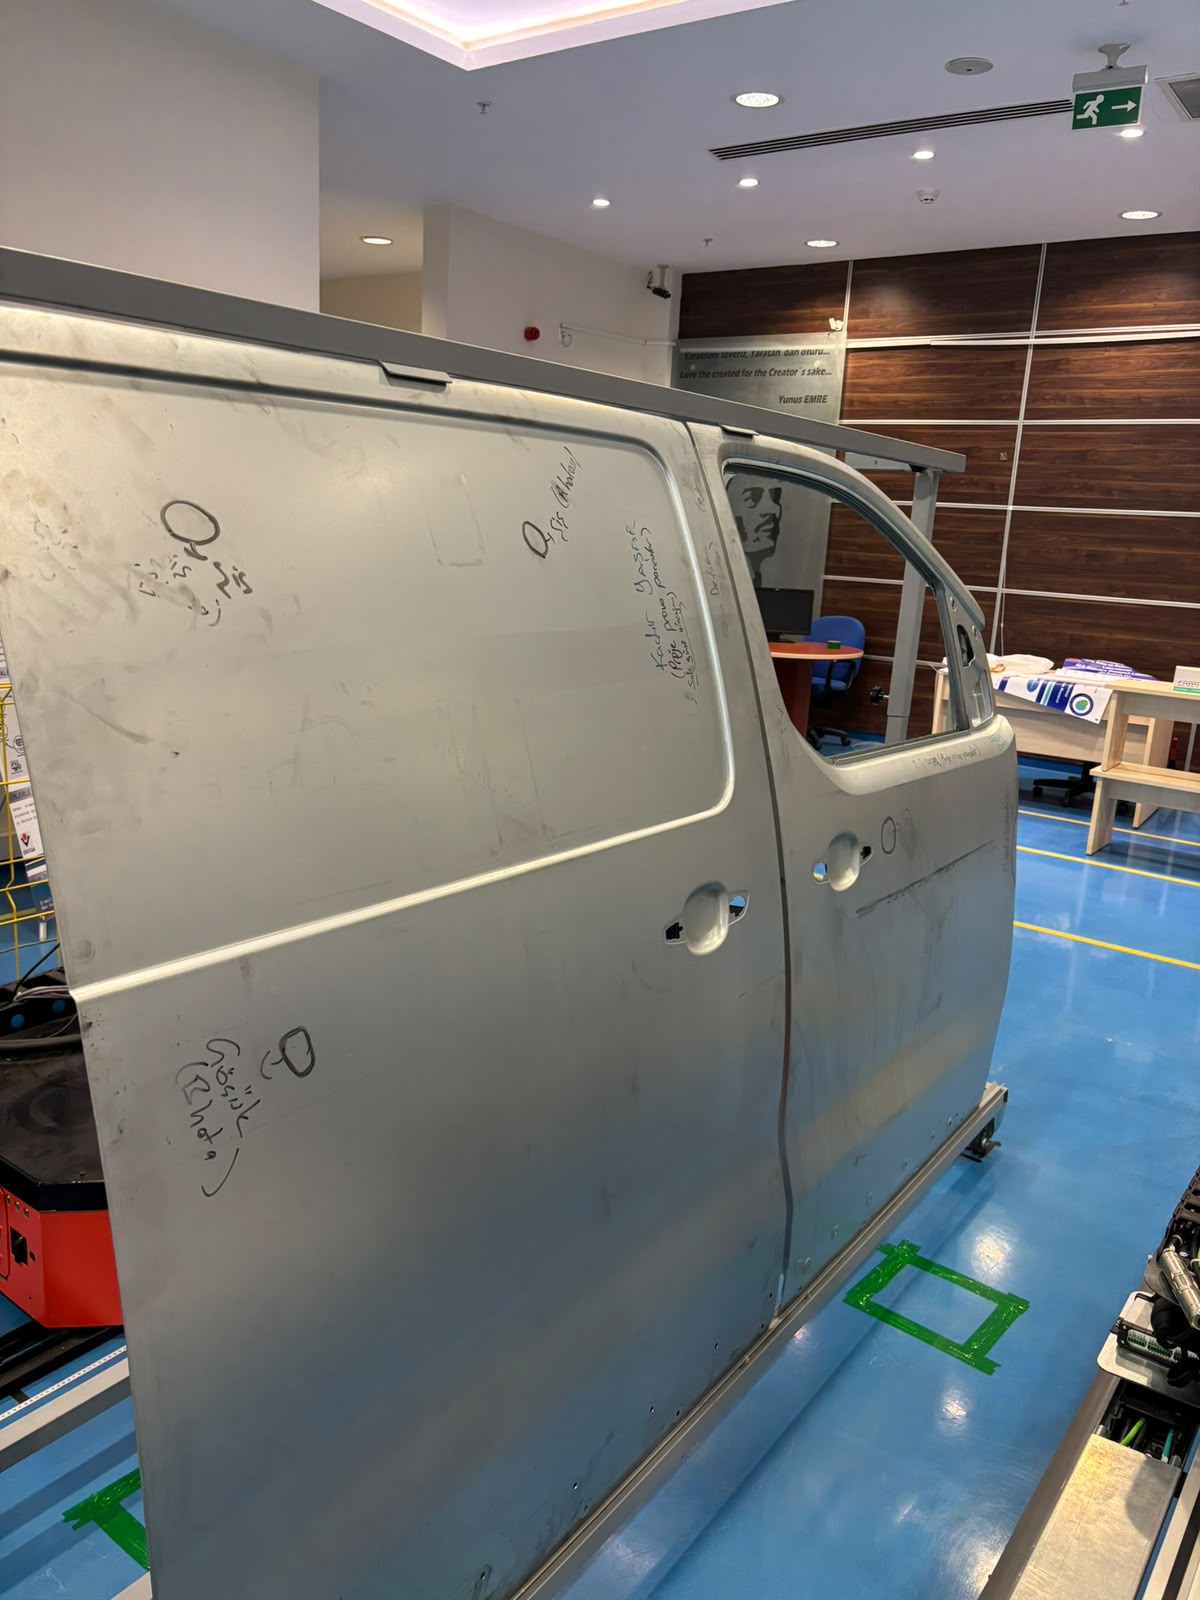
ASRLab uses real Fiat Doblo sheet-metal door panels as experimental workpieces for robot-assisted automotive quality inspection research.
- The panels contain known surface defects and provide realistic test specimens for developing and evaluating computer vision, artificial intelligence, and robotic inspection methods.
- Combined with the UR10e and its linear axis, the setup enables automated camera-based scanning along controlled trajectories and provides a realistic environment for dataset generation and defect-detection experiments.
Research Applications:
Automotive Quality Inspection · Surface Defect Detection · Machine Vision · AI Dataset Collection · Robot-Assisted Inspection
Robotic Screwdriving Station
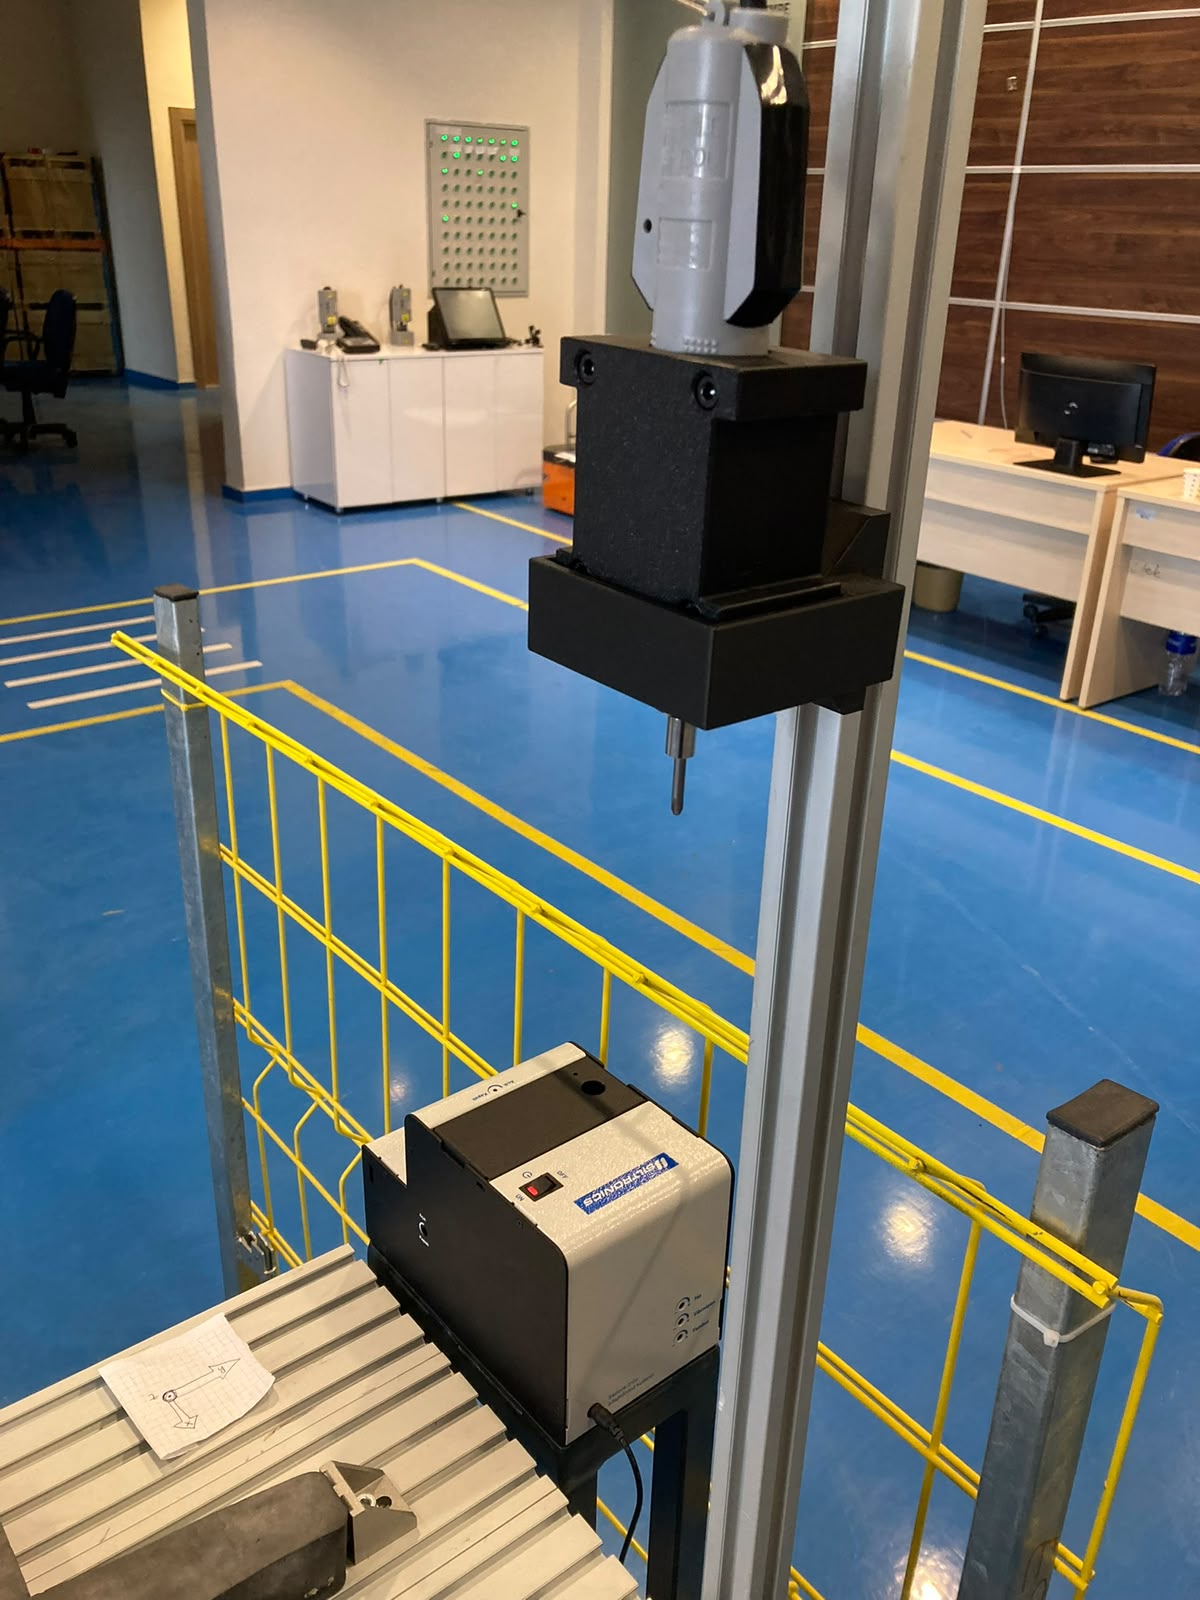
The robotic screwdriving station provides an experimental platform for studying automated assembly and human–robot collaborative manufacturing.
- The setup includes an electric screwdriving tool, an automatic screw feeder, and real industrial workpieces. It can be integrated with the UR10e robot to develop repeatable automated fastening operations.
- The station supports research on robotic screw handling, vision-guided localisation, fastening quality monitoring, automated assembly, and human–robot collaboration.
Research Applications:
Robotic Screwdriving · Assembly Automation · Human–Robot Collaboration · Vision-Guided Assembly · Industrial Robotics
Digital Twins, Simulation & Extended Reality
The physical infrastructure is complemented by ASRLab's research capabilities in Digital Twin engineering, simulation, artificial intelligence, and Extended Reality.
Simulation and Digital Twin environments enable researchers to model system behaviour, execute repeatable experiments, compare physical and virtual system behaviour, analyse operational data, and evaluate systems before or alongside physical deployment.
Extended Reality technologies further support research involving immersive environments, industrial training, human–system interaction, and advanced verification scenarios.
Meta Quest 3
Extended Reality Headset
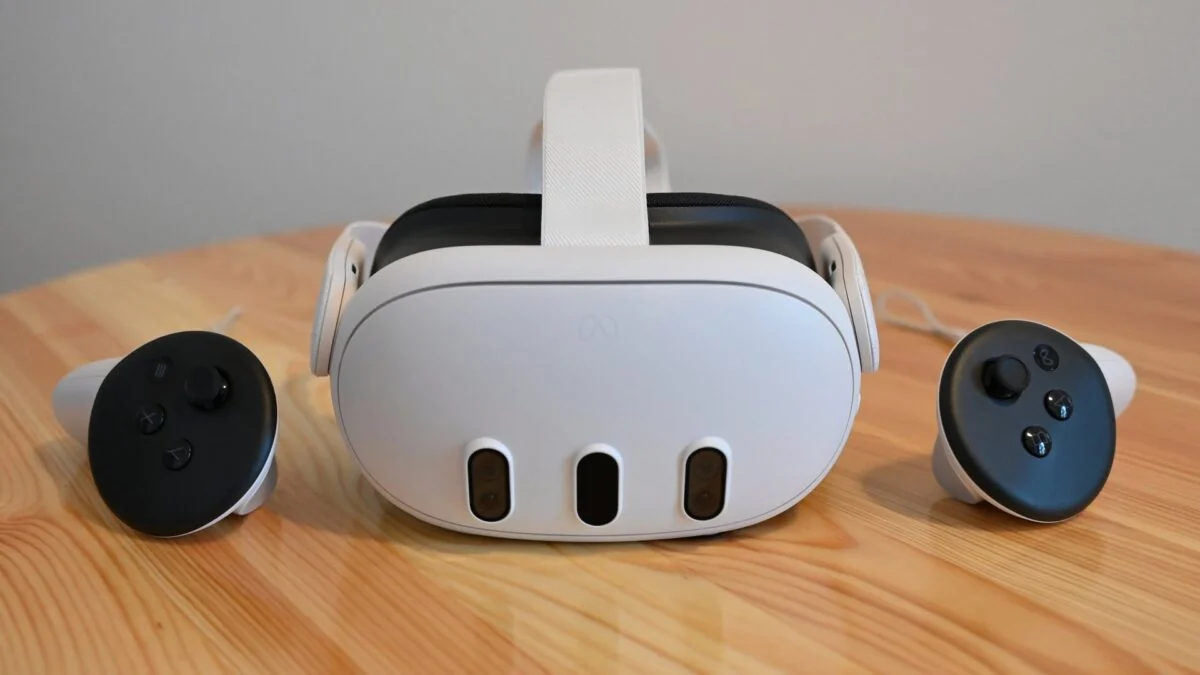
ASRLab uses a Meta Quest 3 headset as part of its Extended Reality research infrastructure.
- The headset supports immersive and mixed-reality experiments involving human–system interaction, industrial training, robotic systems, Digital Twins, and verification and validation scenarios.
- Its integration into experimental workflows enables researchers to develop and evaluate interactive environments where physical and digital systems can be observed, analysed, and experienced through immersive interfaces.
- The platform can also support research on training scenarios, operator assistance, human–robot interaction, virtual prototyping, and the visualisation of Digital Twin data.
Research Applications:
Extended Reality · Mixed Reality · Human–System Interaction · Digital Twins · Industrial Training · Human–Robot Collaboration · Virtual Prototyping
Integrated Research Environment
Together, ASRLab's computing, robotics, automation, simulation, and experimental resources provide an integrated environment for research across the complete engineering lifecycle.
The infrastructure supports activities ranging from AI model development and software testing to robotic experimentation, Digital Twin engineering, physical system validation, computer vision, and industrial automation.
By combining software, computational resources, datasets, simulation environments, and physical experimental platforms, ASRLab supports both academic research and industry-oriented R&D activities.